Sense force and pose together
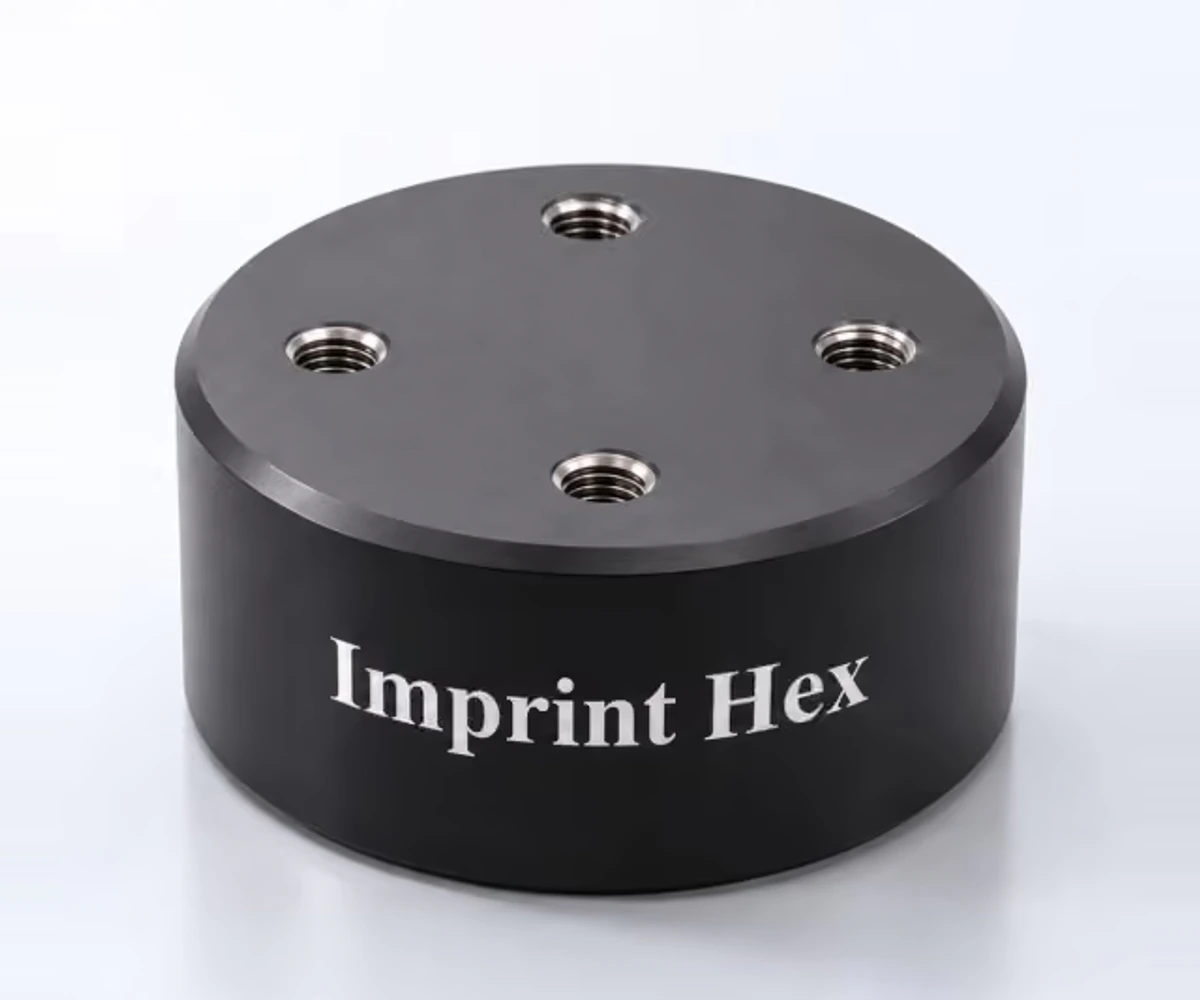
Combines force / torque and 6D pose sensing for synchronized contact feedback.

Flexible six-axis force sensor
Sense force and pose together
Combines visuotactile sensing and a compliant structure to sense six-axis force and pose simultaneously, supporting hybrid force–position control for assembly, precision finishing and human–robot interaction.
Sense force and pose together
Combines force / torque and 6D pose sensing for synchronized contact feedback.
A compliant design for contact tasks that require both precision and flexibility.
Senses force and position across multiple independent channels for manipulation control.
Supports automated assembly, precision finishing and human–robot interaction.
From assembly to finishing, combine precision with compliance.
| Mechanical behavior | Compliant |
|---|---|
| Sensing dimensions | Force / torque + 6D pose sensing |
| Sensing channels | Independent force and position sensing across multiple channels |
| Full-scale error | 1–5 FS% (as stated in the manufacturer brochure) |
| Control | Supports hybrid force–position control |
| Applications | Finishing and polishing, massage, human–robot interaction, exoskeleton joints |
Explore how Imprint Hex fits your manipulation task.
Share your hardware, objects and capture requirements so we can arrange a relevant product demonstration.
Request a demonstration